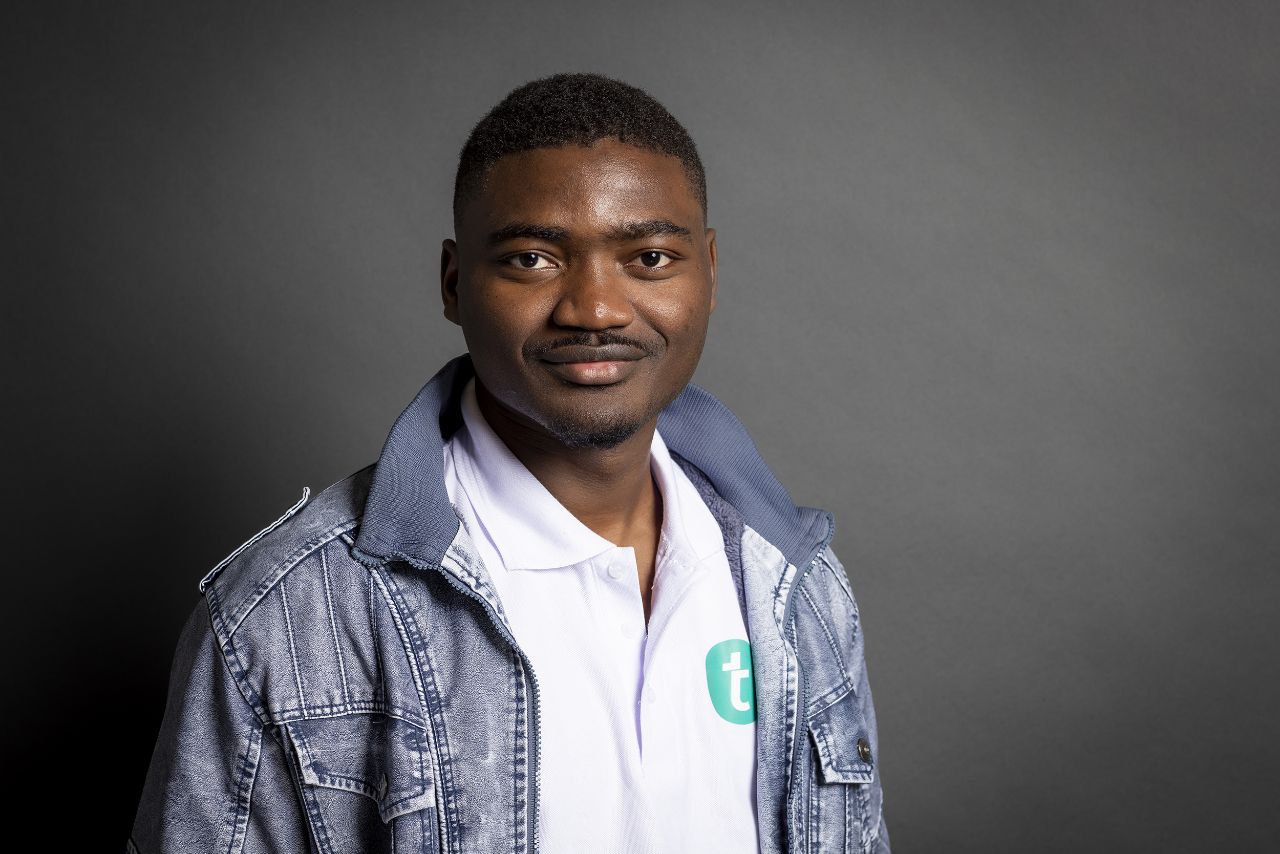
Available from 1 January 2027

Batchaya Yacynte —
Perception engineer.

Building the vision systems that let machines navigate when GPS fails. M.Eng. AI Engineering & Autonomous Systems · TH Ingolstadt · Airbus Helicopters consortium.

Batchaya Yacynte
4+
Years building
perception systems
0.15°
Rotation accuracy
Project ENGEL (simulation)
1st
Author IEEE publication
REM 2024
3
Real hardware platforms
validated outdoors

Affiliated with

TH Ingolstadt - M.Eng. Airbus Helicopters Consortium Fraunhofer IVI AIMotion Bavaria IEEE REM 2024 - First Author

About

Engineer, researcher,
builder.

I'm a Cameroonian robotics engineer based in Ingolstadt, Germany. My work lives at the boundary where computer vision, probabilistic estimation, and control systems meet, building perception pipelines that have to perform on real hardware, outdoors, under pressure.

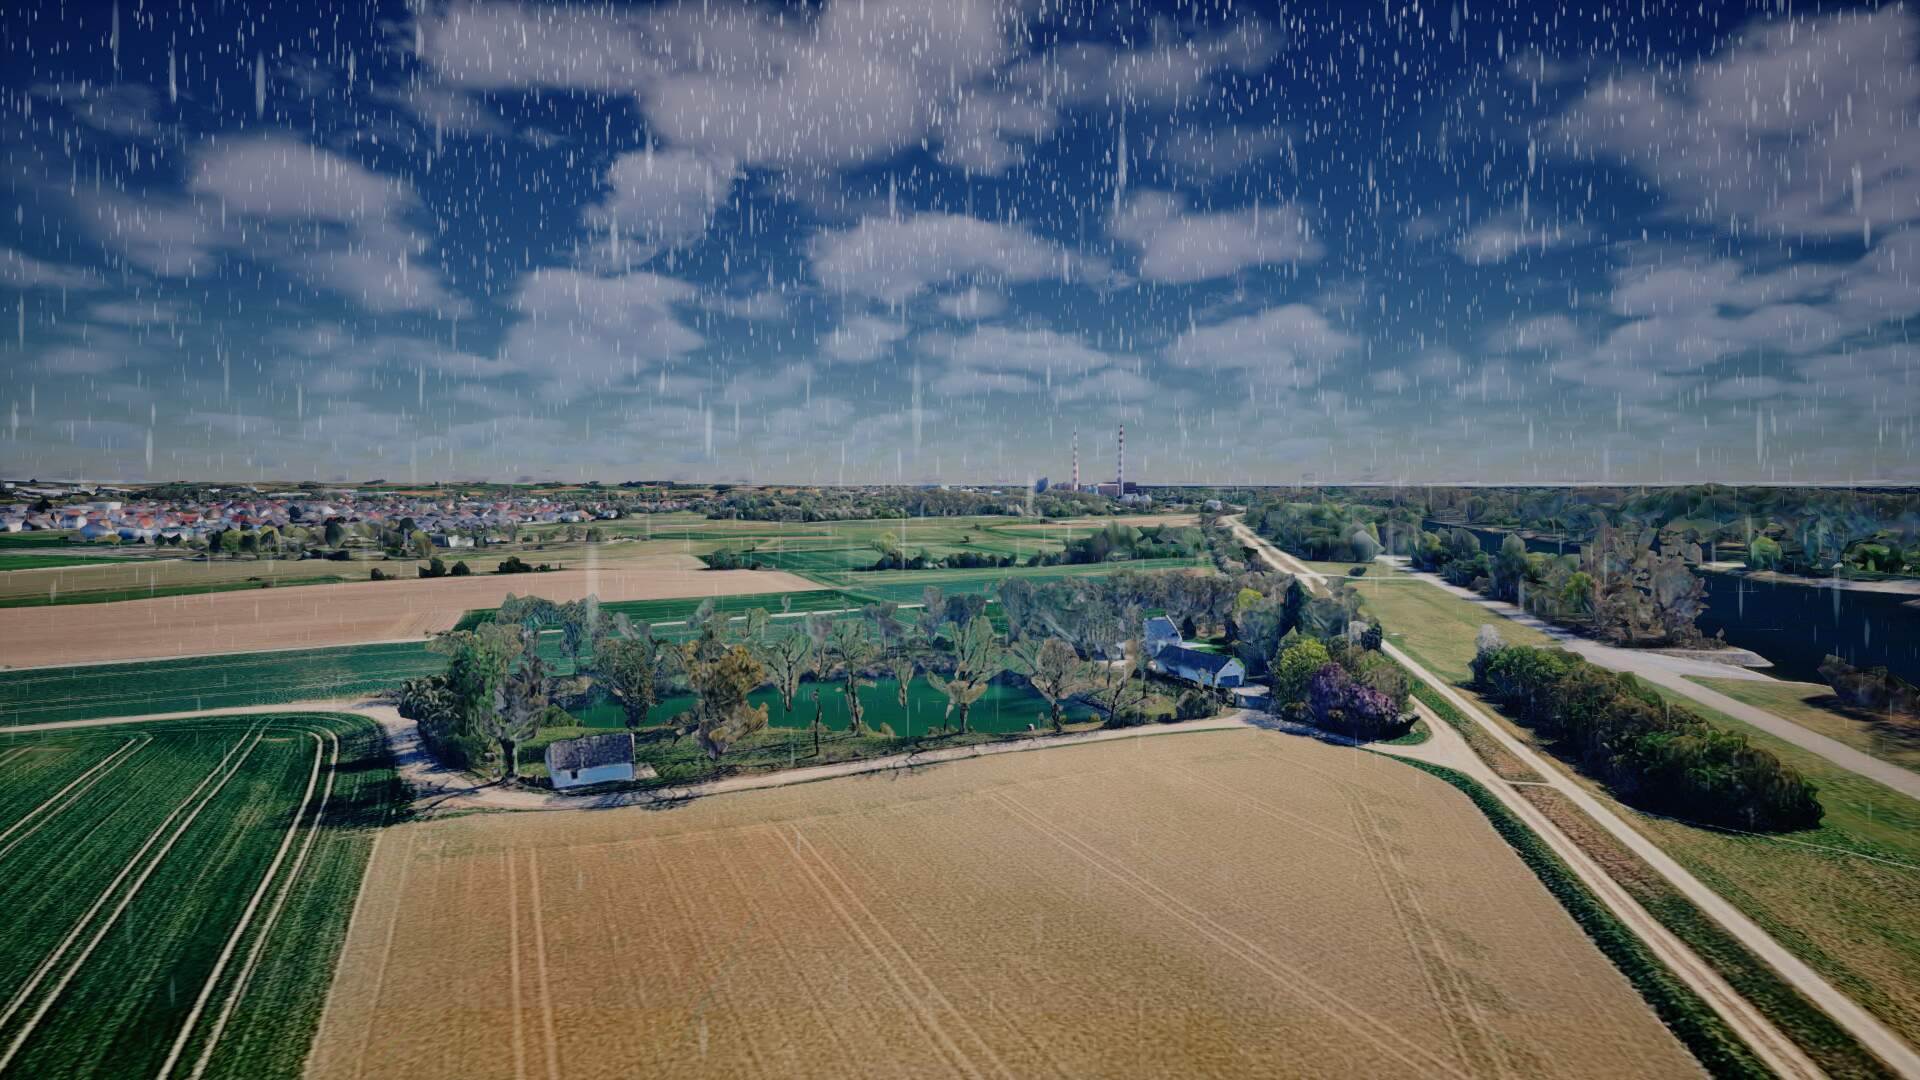
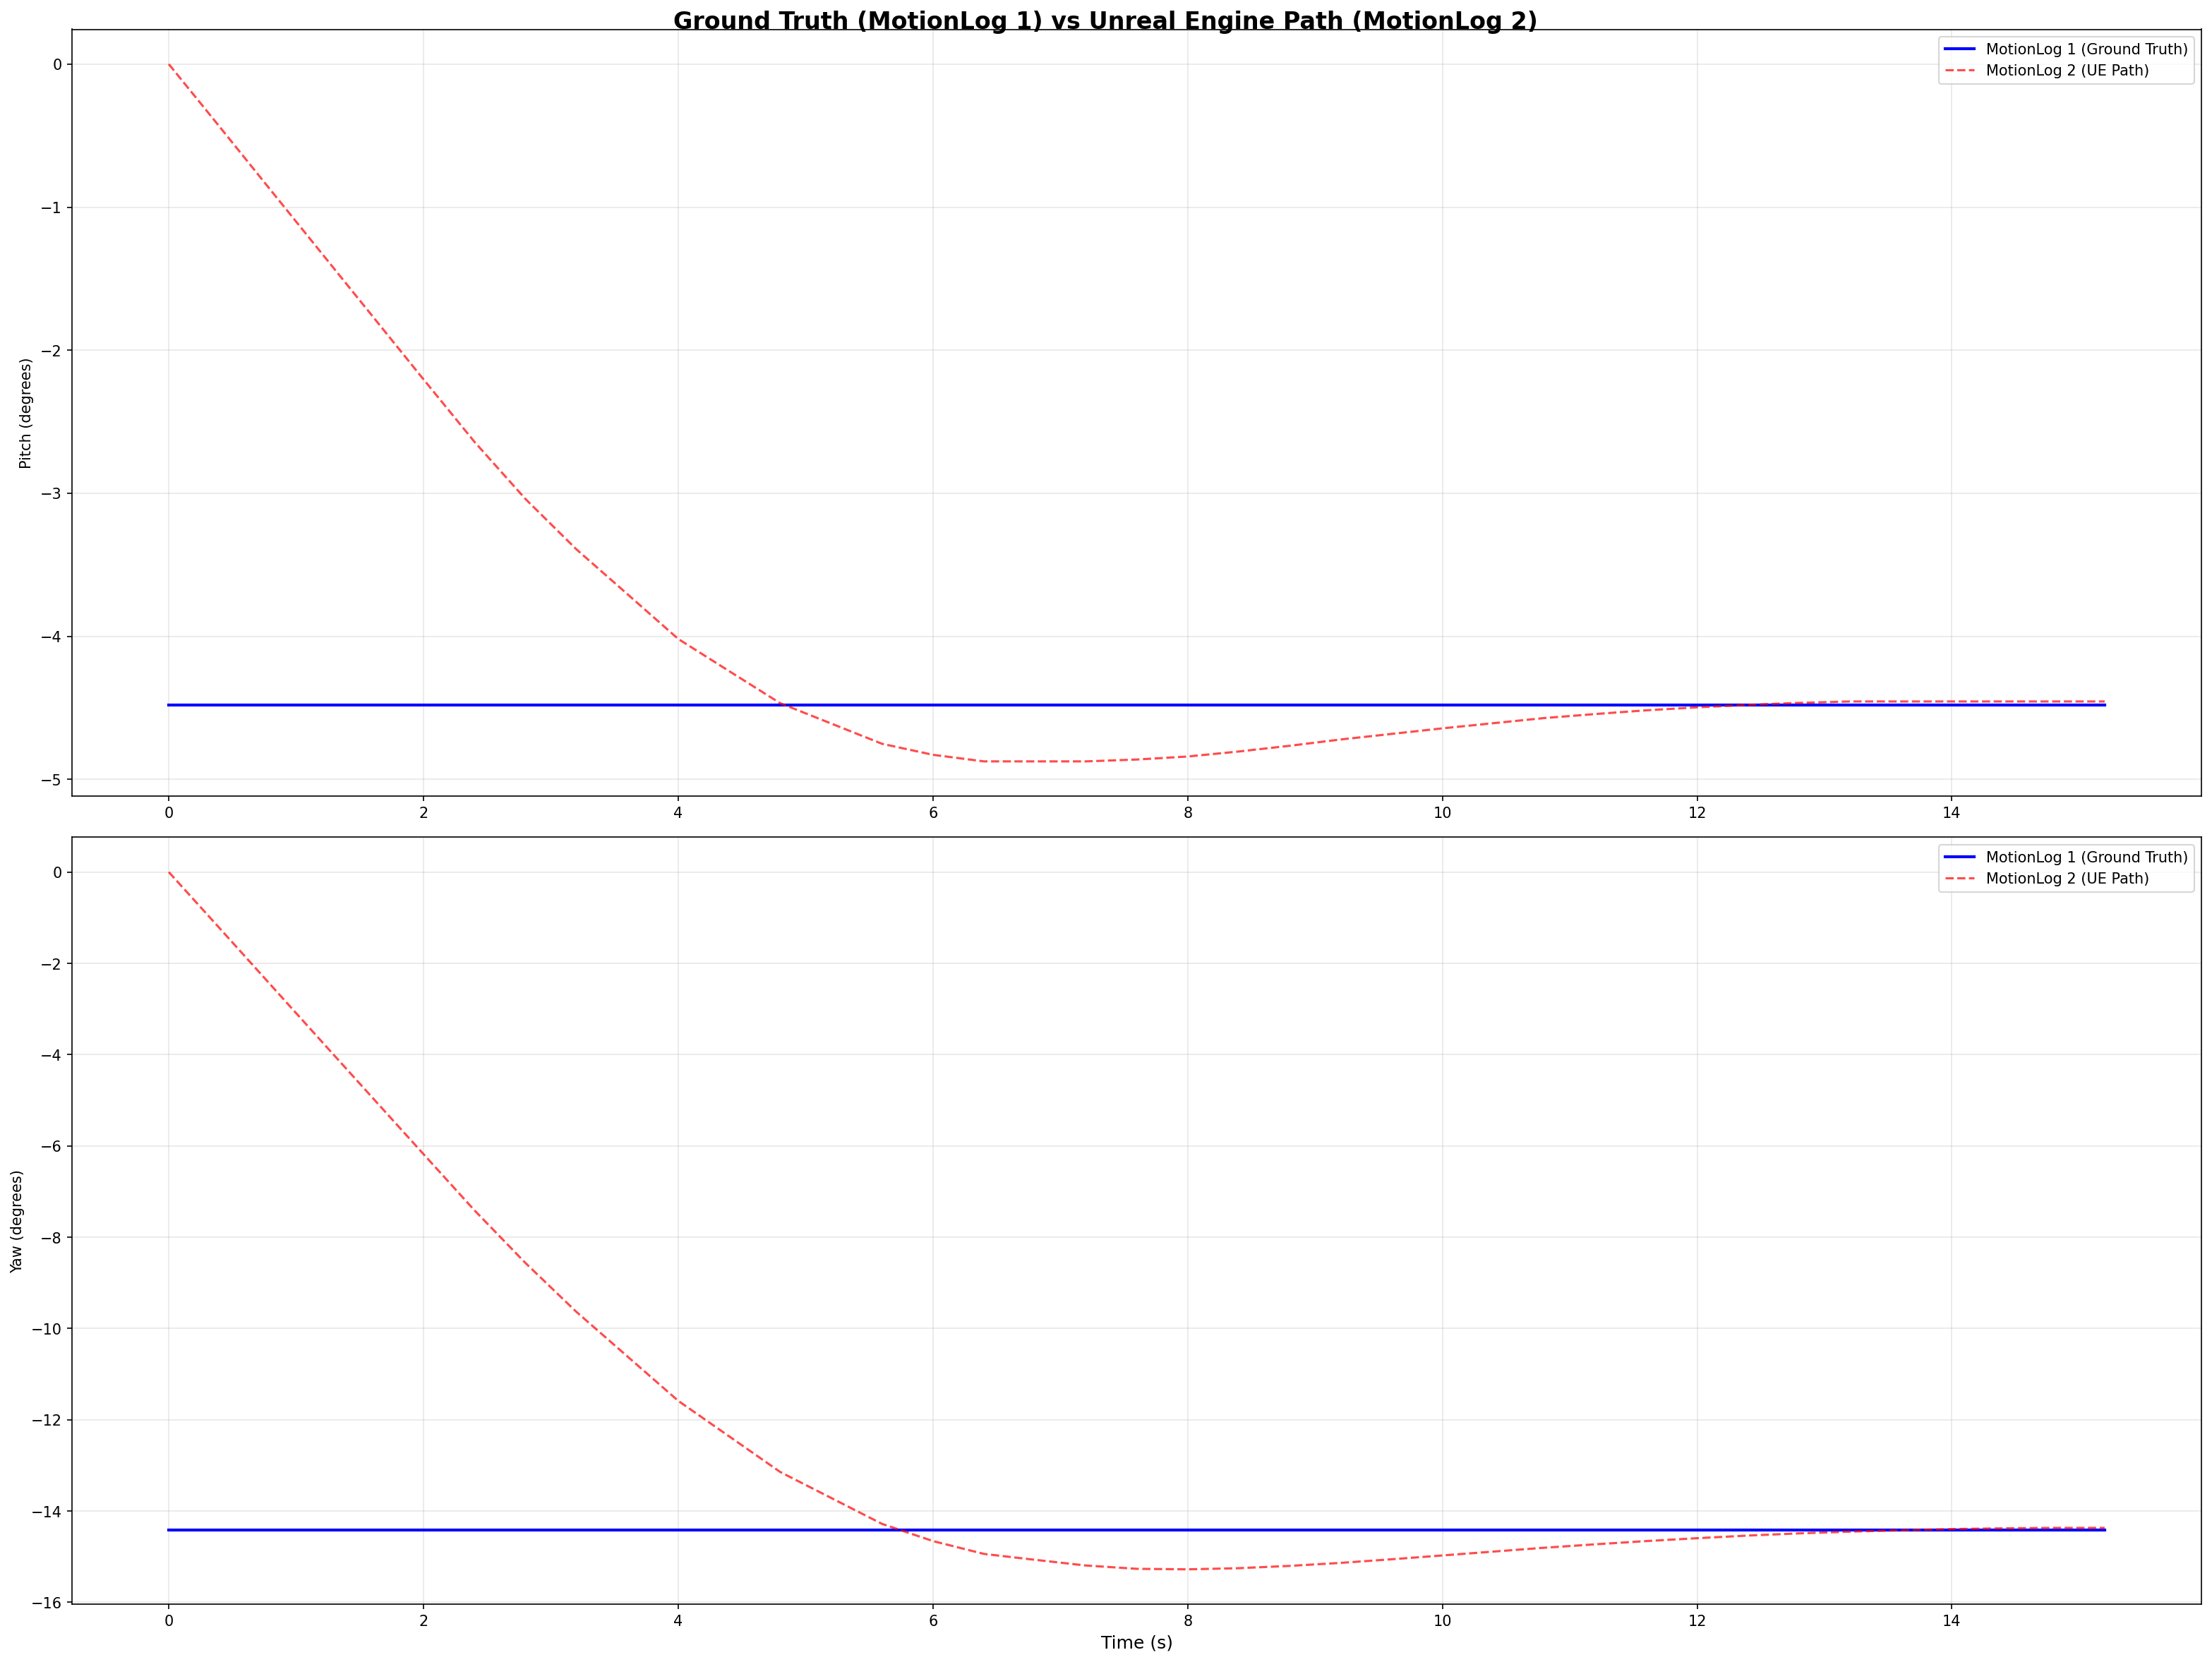
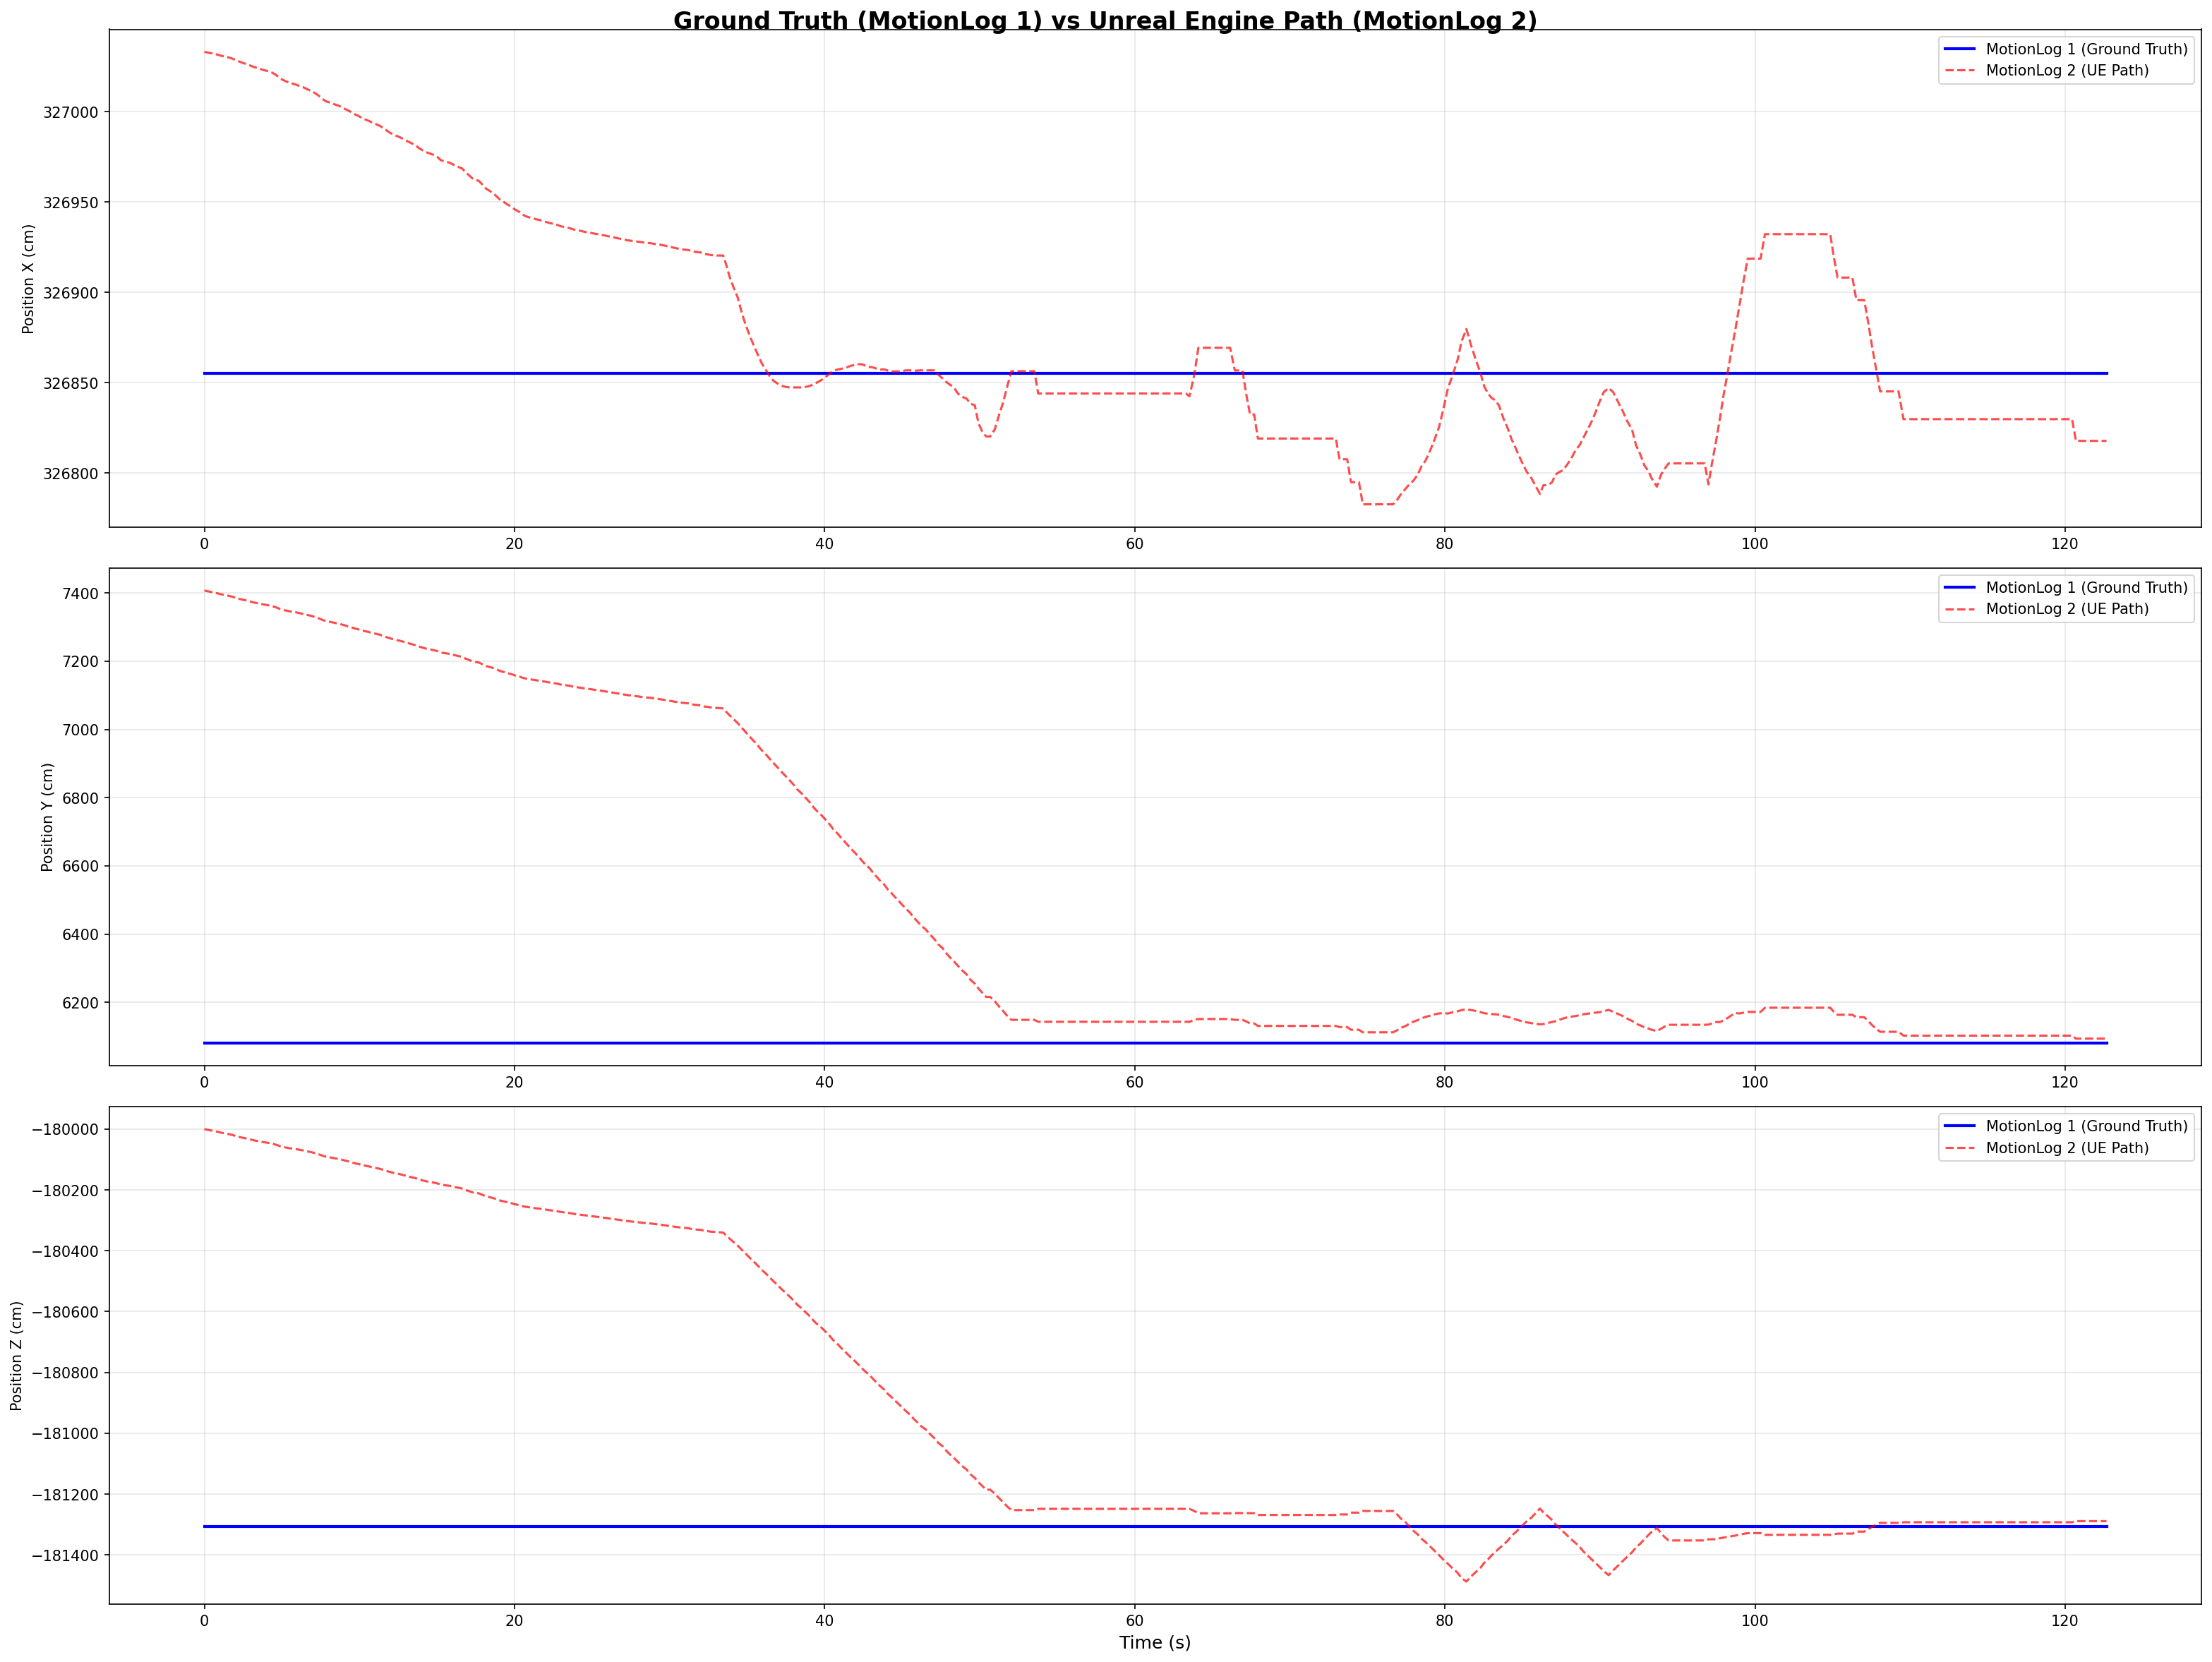
My master's thesis, developed within an Airbus Helicopters consortium, returns a UAV camera to the viewpoint of a reference image using only an onboard monocular camera. In 234 Unreal Engine 5 simulation trials across clear weather, rain, snow and fog it reaches 0.15° rotation accuracy and about 2 px image alignment in clear weather; first tests on the real drone cover the gimbal (rotation) loop. Before that, at Fraunhofer IVI, I designed an event-based optical flow system for Time-to-Collision estimation that outperformed three state-of-the-art methods on the MVSEC benchmark, running single-threaded on NVIDIA Jetson.

I care about systems that work outside the lab. My work is validated on KITTI, EuRoC, custom DJI Tello flights with OptiTrack ground truth, and live outdoor field tests, not just in simulation.


Selected work

Projects that ship.

Real-world perception systems, embedded deployments, and autonomous platforms, from Airbus-consortium UAVs to Fraunhofer agricultural robotics.

02
Research · KoSiNuS Fraunhofer IVI Apr 2025 – Mar 2026
Event-Based Optical Flow for Real-Time TTC Estimation
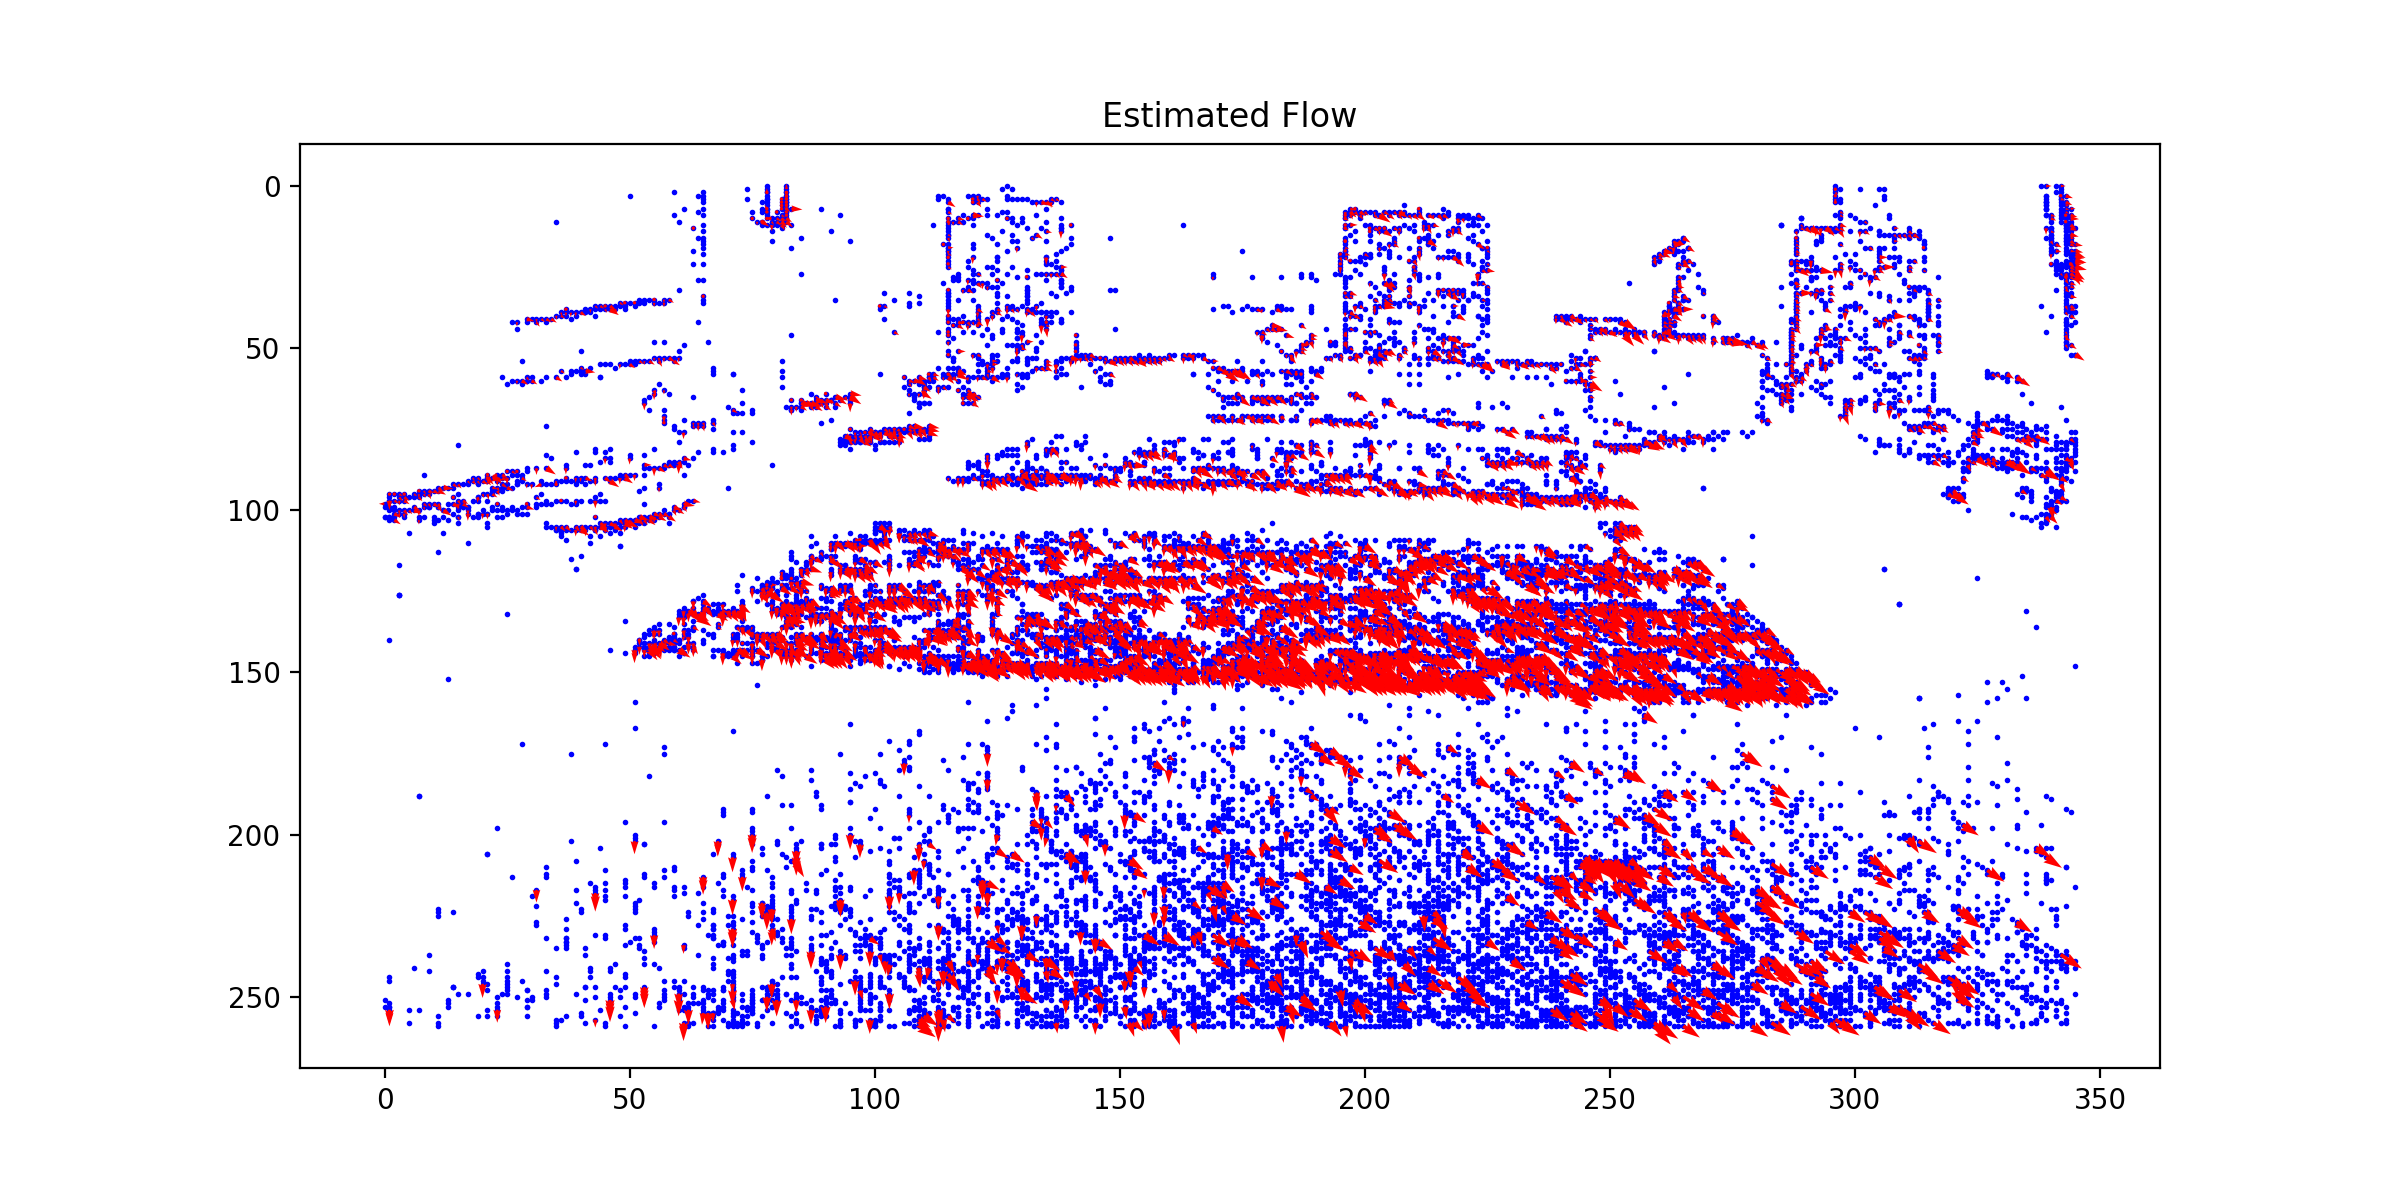
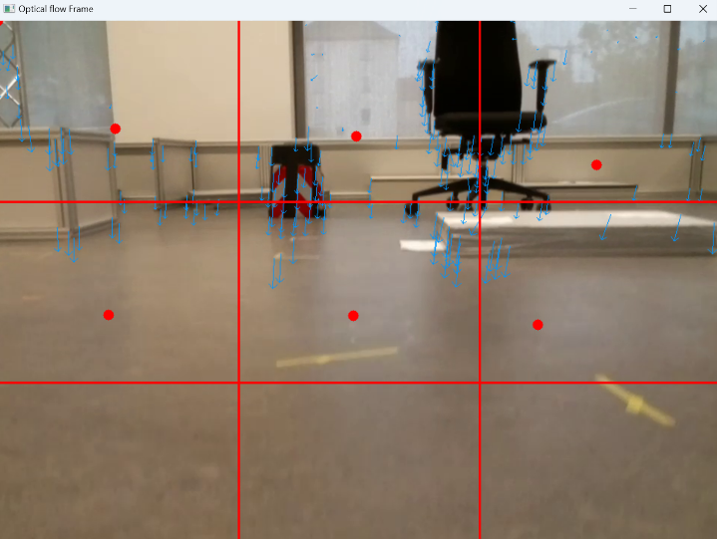
Probabilistic event-based optical flow pipeline for Time-to-Collision estimation in safety-critical agricultural autonomy. Gaussian residual model with motion-adaptive variance scaling and affine RANSAC outlier rejection, integrated into ROS2 with an IDS uEye DVS sensor on NVIDIA Jetson embedded hardware.
2.33 px AEPE Outperforms UnFlow, EV-FlowNet, Shiba et al. 3.5 Meps single-threaded on Jetson Orin
Event-based optical flow compared with ground truth
KoSiNuS · Event Flow
–
03
Personal Project Custom UAV Build
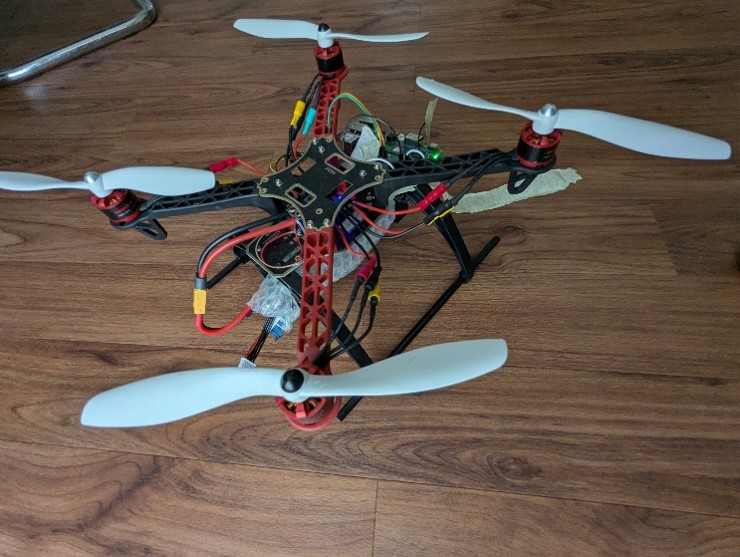
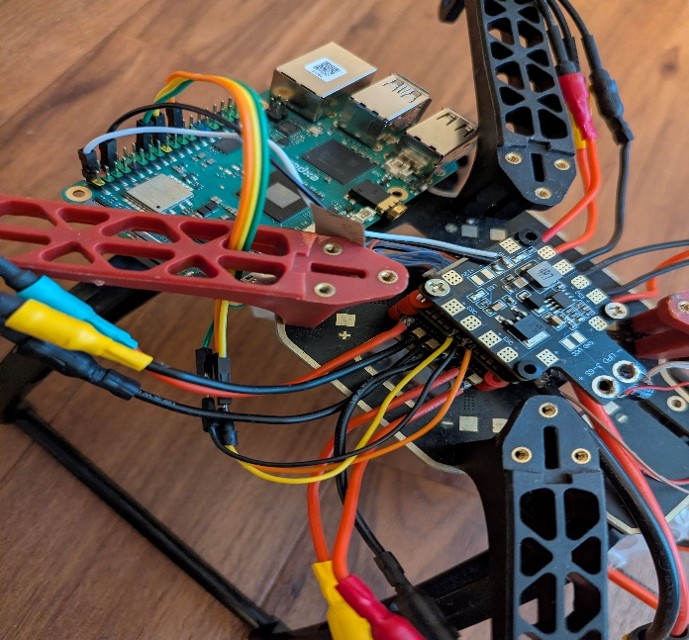
Autonomous Surface Area Mapping Drone
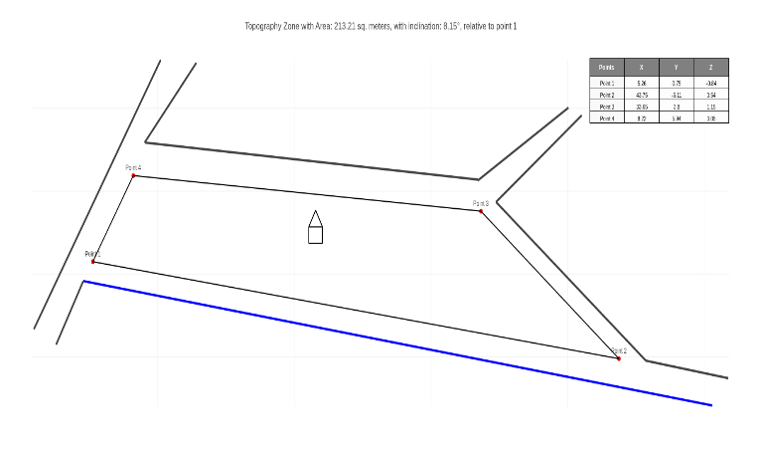
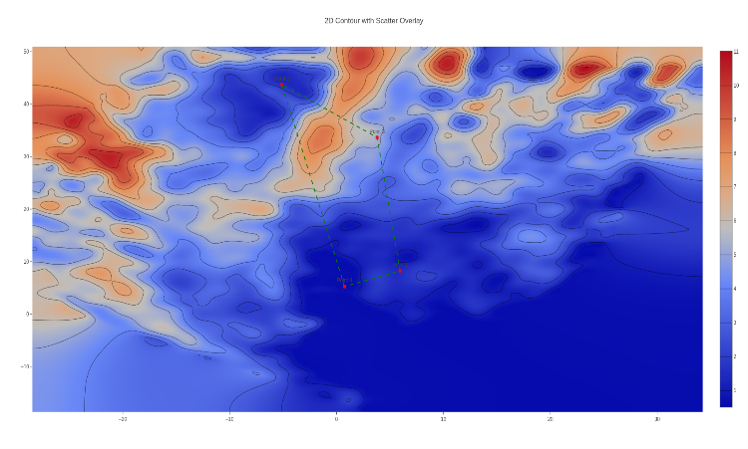
Designed and hand-built a custom ~25×25 cm UAV (Betaflight F405 V3 + Radxa A7A) and developed a full stereo vision pipeline for autonomous land surface area measurement. Targets agricultural and surveying use cases as a low-cost alternative to total stations. Full pipeline from stereo depth estimation to contour detection and geometric area computation, generating topographic and plat map outputs.
KITTI validated Topographic + plat map outputs Custom hardware build
Beetle, the custom-built mapping drone Beetle drone hardware close-up Topographic map produced by the stereo pipeline Plat map with computed surface area
Beetle · Maps
–
04
Course Project Grade 1.0 2025 – 2026
Deep Visual-Inertial Odometry Pipeline
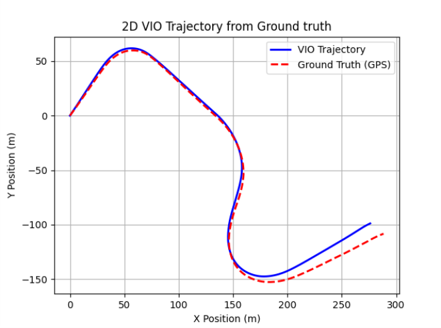
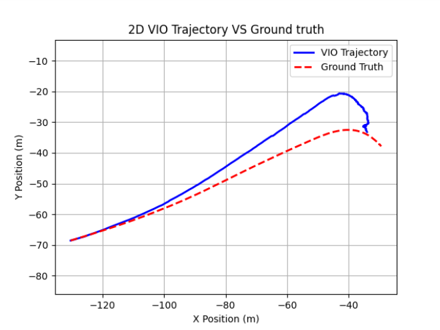
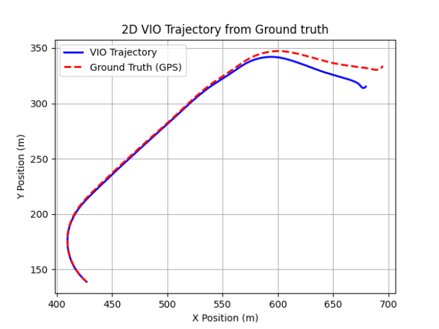
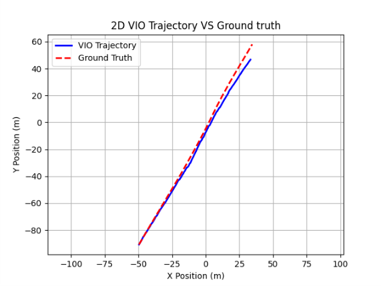
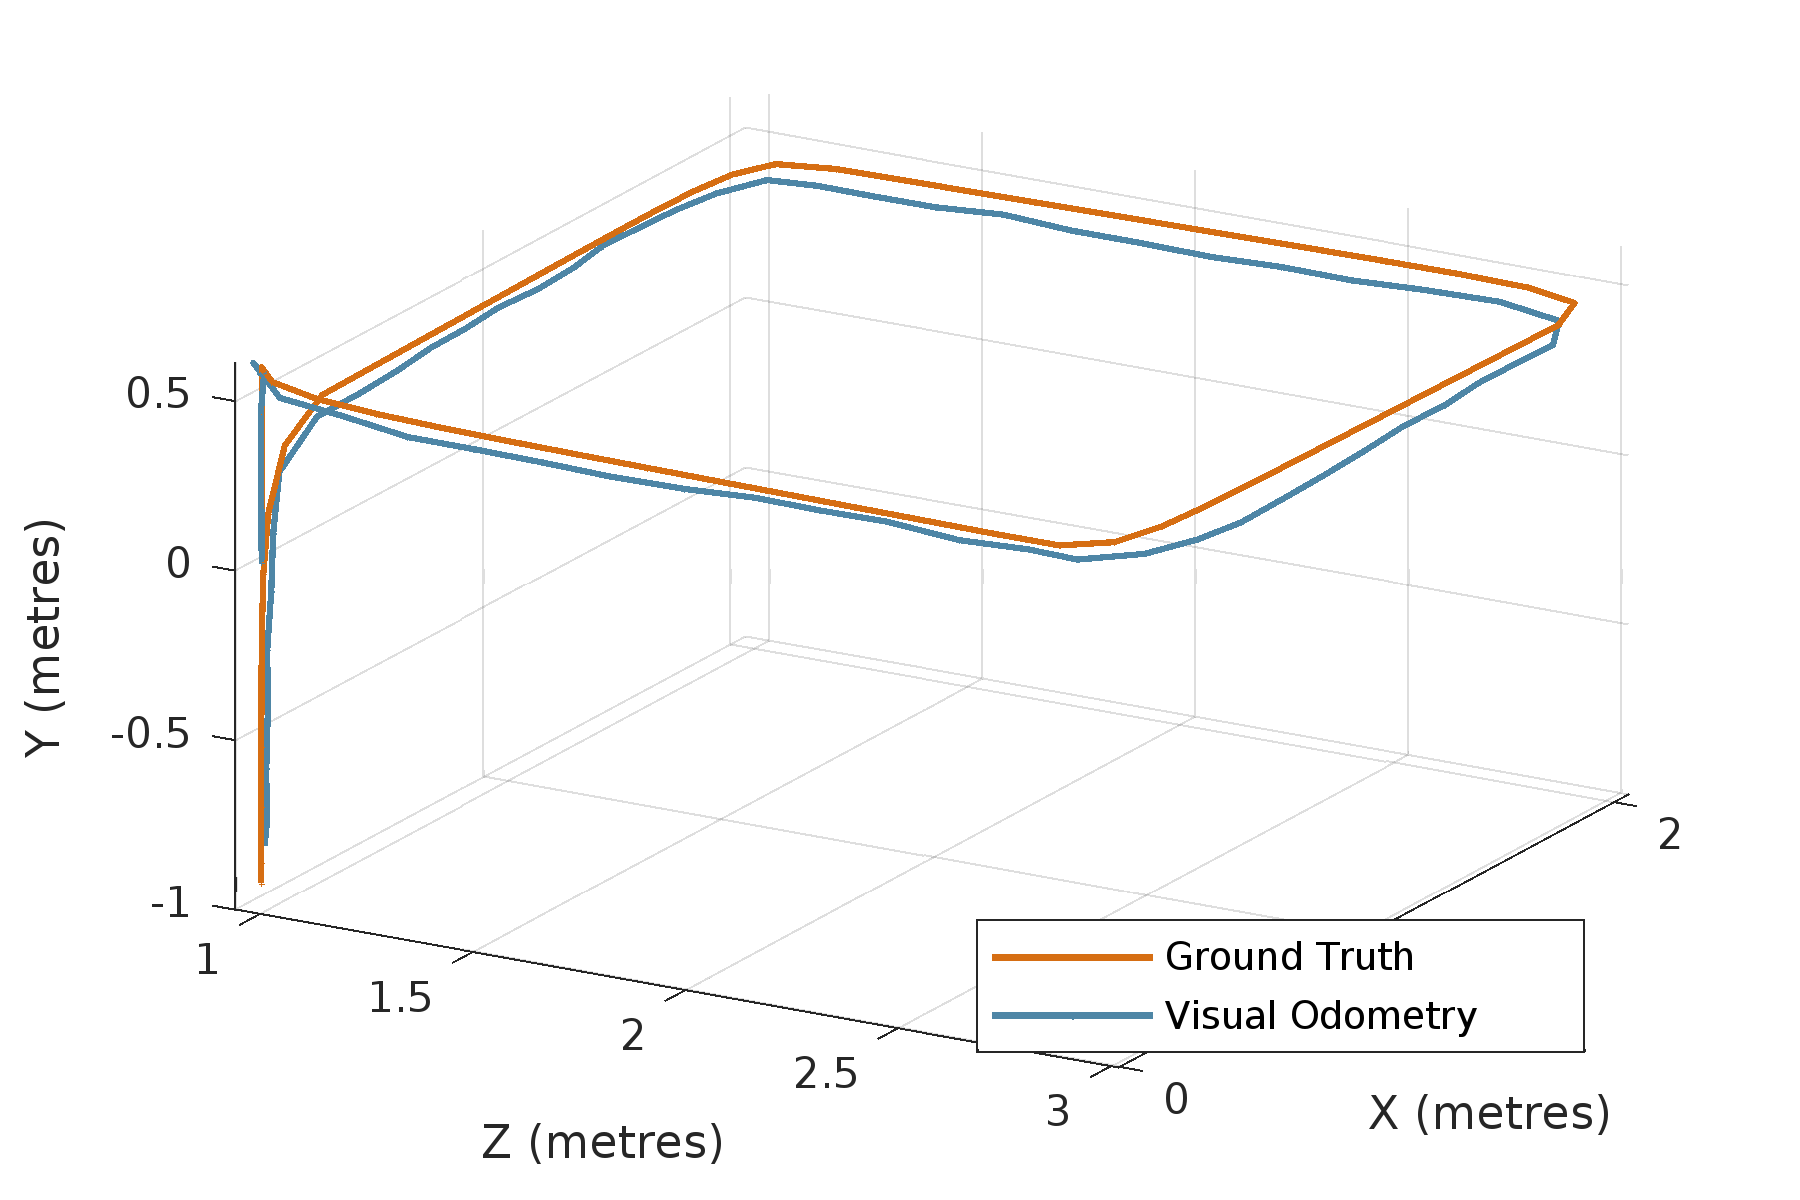
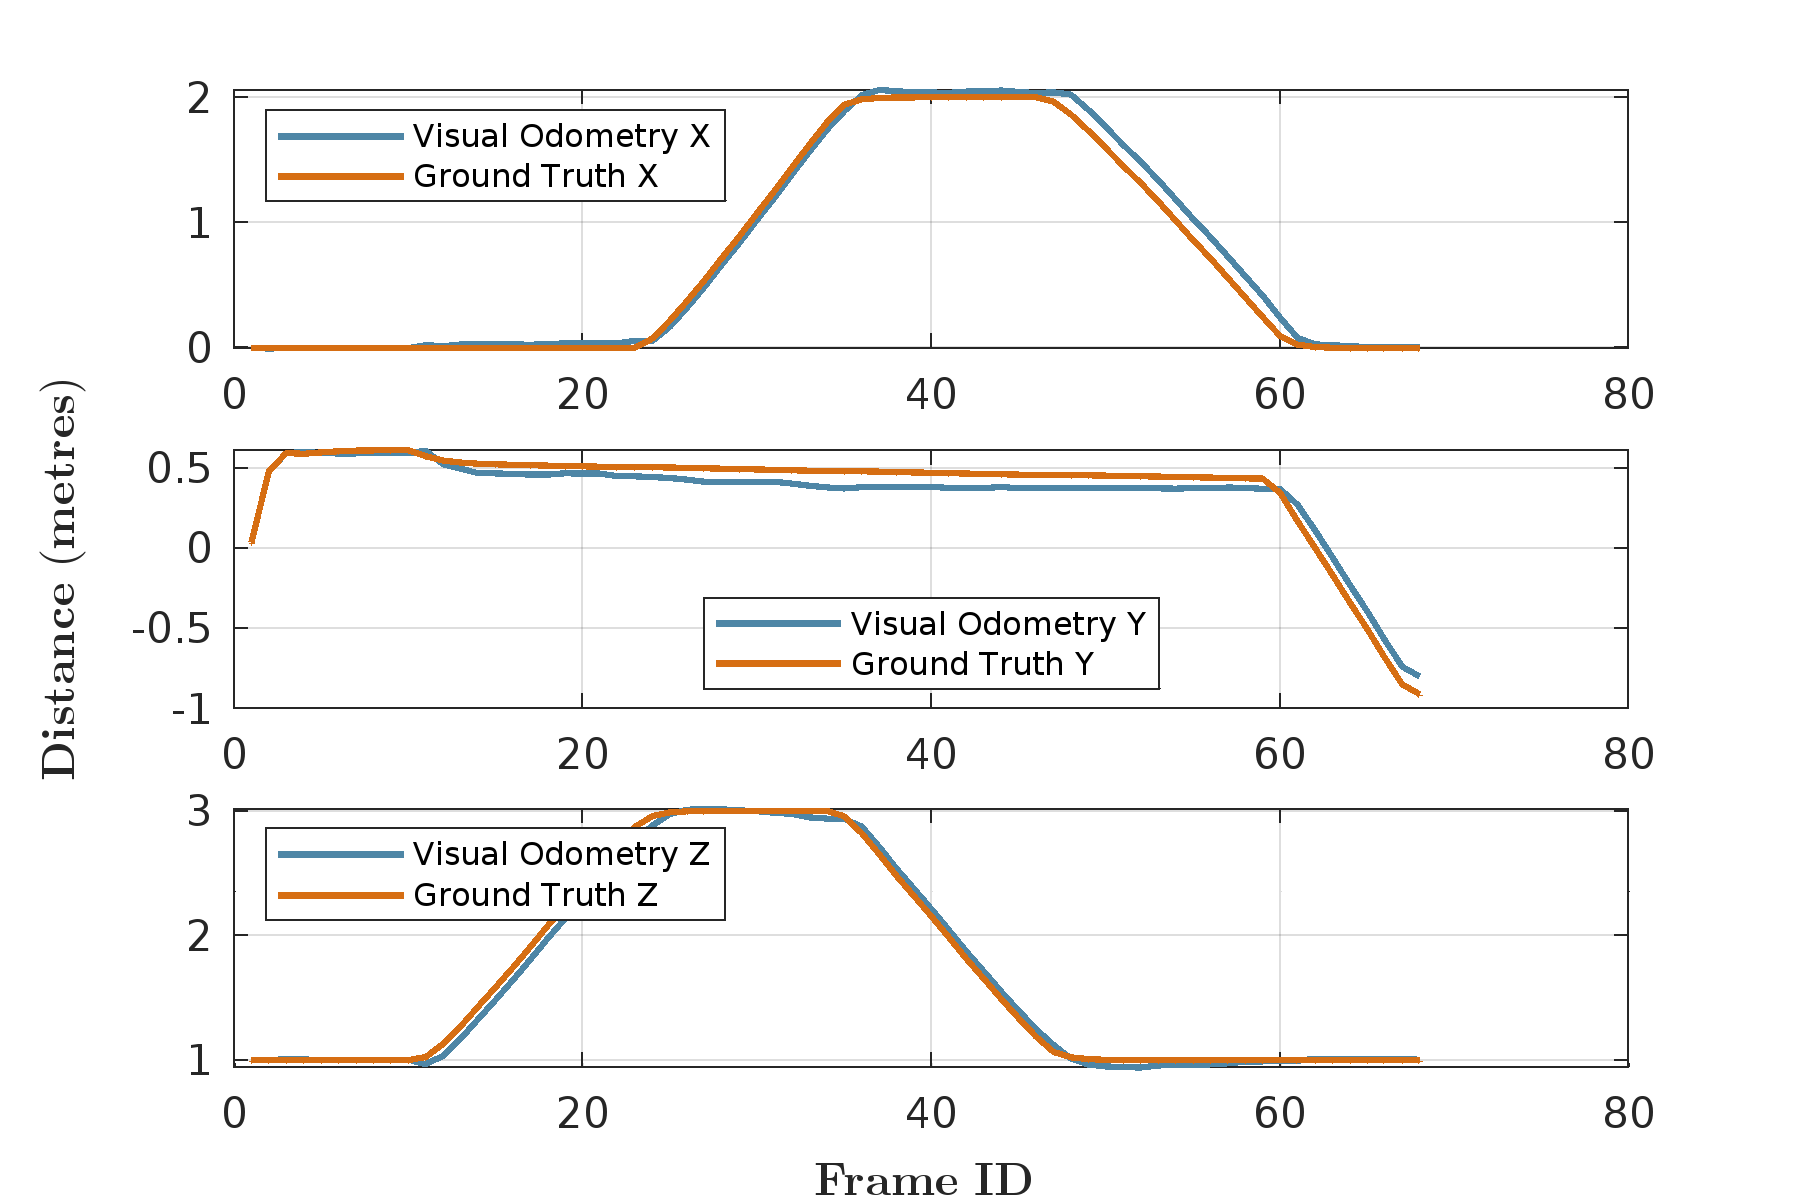
End-to-end deep learning VIO system for GPS-free 6-DoF localization, fusing monocular camera and IMU measurements with CNNs. Evaluated on EuRoC MAV for indoor flight and KITTI for outdoor driving scenarios.
0.038 m ATE — EuRoC MAV 1.42 m ATE — KITTI
Deep VIO estimated trajectory on KITTI Deep VIO trajectory compared with ground truth Deep VIO estimated trajectory on KITTI Deep VIO trajectory compared with ground truth
Monocular · VIO · Learning
–
05
Robotics Engineering CAD & Mechatronics Personal / Industrial
Robotic Systems & Mechanical Design
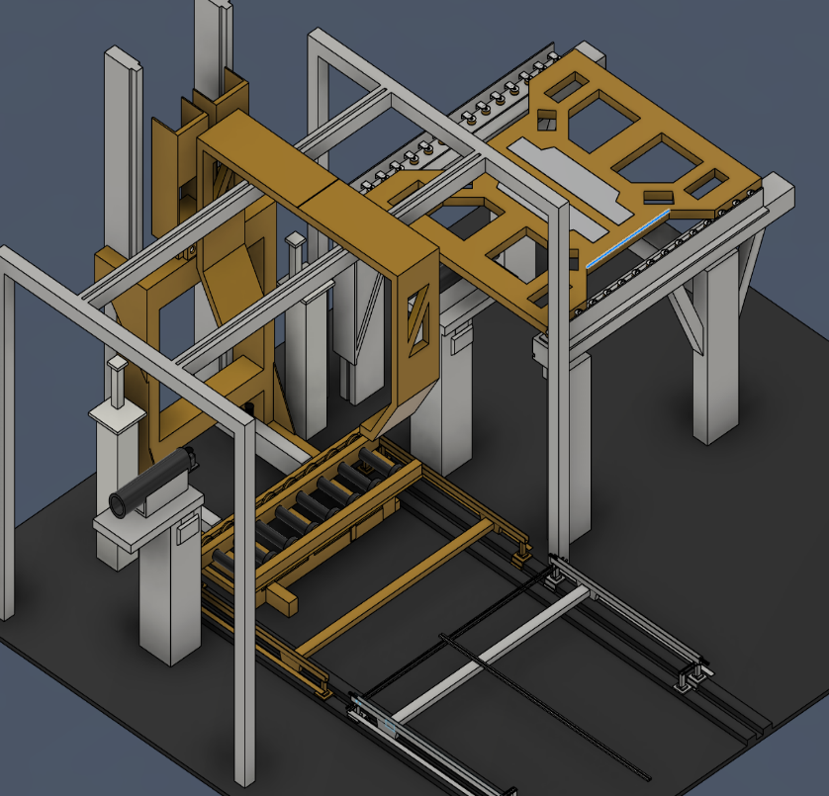
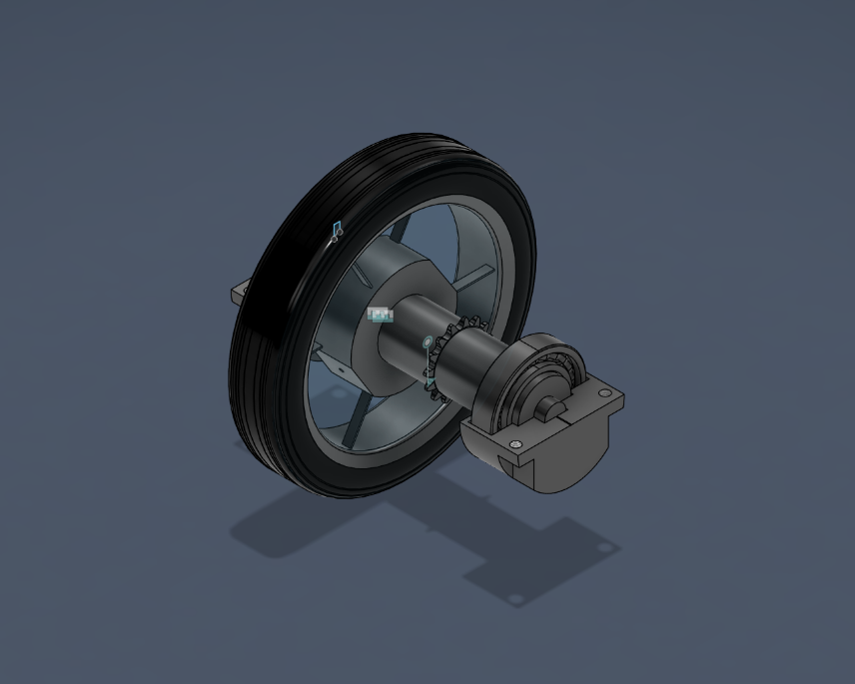
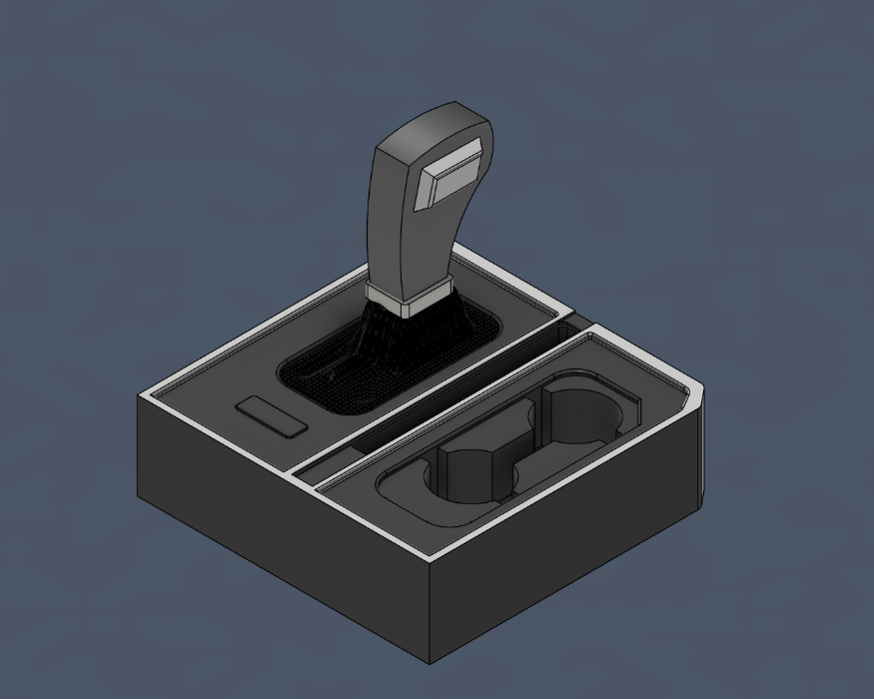
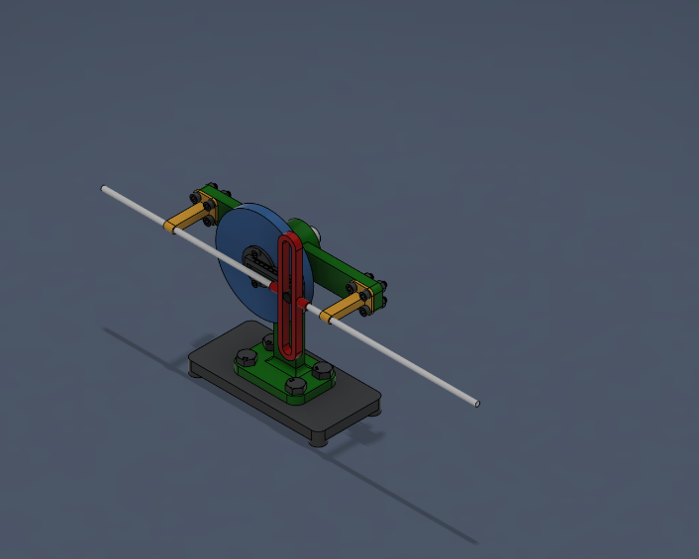
Mechanical and mechatronic engineering projects spanning robotic systems, CAD design, vehicle assembly-line concepts, and agricultural robotics. Designed mechanical assemblies and integrated them with electronics, actuators, sensing, and autonomous control concepts.
CAD design Robotic assemblies Agricultural robotics Mechatronic systems
Vehicle assembly-line concept CAD Wheel assembly CAD model Gearbox CAD model Agricultural seeding robot prototype
Robotics · CAD
↗

Publication

Peer-reviewed research.

IEEE REM 2024 · First Author · DOI: 10.1109/REM63063.2024.10735689
Getting Started With a Simple Visual-Inertial Odometry
Batchaya, Y. D. et al. — Presented at IEEE REM 2024 · Published in IEEE Xplore
IEEE Xplore ↗

Contact

Let's build
something real.

Looking for robotics and computer vision roles in Germany starting 1 January 2027. Eligible for an EU Blue Card or the post-study job-seeker permit. If you work on autonomous systems, UAVs, or embedded perception — let's talk.